Hi! I am Weijue Bu, an incoming graduate student at the Institute of Trustworthy Embodied Artificial Intelligence (TEAI), Fudan University. I am currently a computer science undergraduate at China University of Mining and Technology (2023 – present). From December 2025 to August 2026 I was a research intern at Tsinghua Shenzhen International Graduate School, working on robotic manipulation and vision-language-model-based planning. I am now an embodied AI algorithm intern at Noematrix in Shanghai, having joined on October 26, 2026.
My research interests include agentic robotics, embodied reasoning, spatial intelligence, and long-horizon robotic manipulation.
My current focus is agentic robotics and embodied reasoning — vision-language models that reason about the physical world and drive robots through long-horizon manipulation tasks. Longer term, I want to work on RSI (recursive self-improvement) in Embodied AI.
News
Joined Noematrix as an Embodied AI Algorithm Intern.
Awarded the National Scholarship (2025–2026 academic year).
Admitted to the Institute of Trustworthy Embodied Artificial Intelligence (TEAI), Fudan University, as an incoming graduate student.
Paper RoboStream accepted to ECCV 2026.
Paper CALO accepted to IEEE Transactions on Cloud Computing.
Paper Conscious Gaze accepted to ICME 2026.
Won National First Prize in the "Challenge Cup" Competition.
Awarded Academic Potential 1st Prize at SJTU Summer School.
Publications
Peer-reviewed Conference
ECCV 2026 Project Page · Code · arXiv
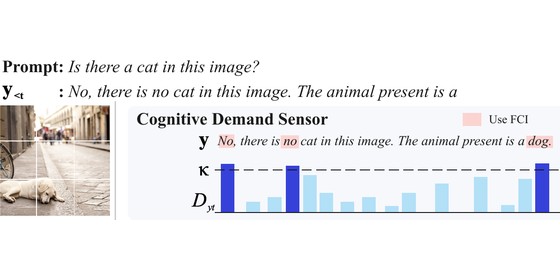
ICME 2026 arXiv
Peer-reviewed Journal
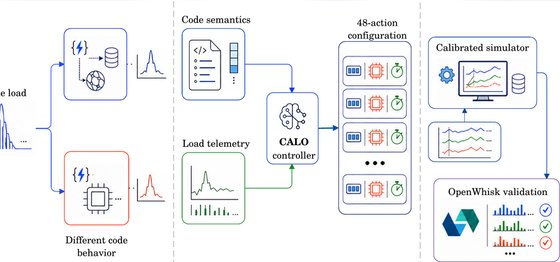
IEEE TCC 2026 Code
Preprints & Under Review
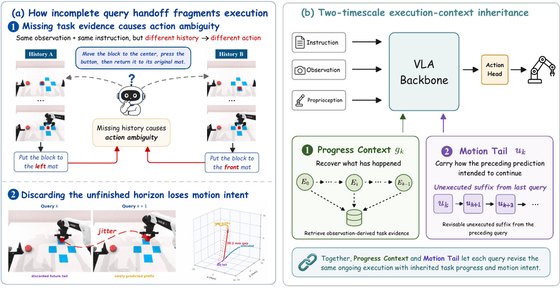
Under review Project Page
Under review
* Equal contribution.
Open Source
Experience
Working on embodied AI post-training.
Tsinghua University
Long-horizon robotic manipulation and vision-language-model-based planning. Built the RLBench / SIMPLER evaluation pipeline and designed long- and short-horizon task suites; co-developed RoboStream (ECCV 2026) and worked on VLA execution-state memory.
Awards & Honors
National Scholarship (2025–2026 academic year)
Second Prize, 15th "China Software Cup" Collegiate Software Design Contest, National Finals (Higher Education Group)
National First Prize, "Challenge Cup" Unveiling Competition
15th Place, Tianchi Alibaba Mobile Recommendation Algorithm Challenge
Academic Potential 1st Prize, SJTU Natural Sciences Institute Summer School
Second Prize, RAICOM Jiangsu Division Programming Skills Competition
Bronze Medal, ICPC China Invitational
Second Prize (Provincial), Lanqiao Cup C/C++ Programming
Second Prize (Provincial), Jiangsu Higher Mathematics Competition
Third Prize (National), GPLT Group Programming Ladder Tournament
Reflections
Three years ago, efficiency was the lens through which I often viewed computer science. Today, I am increasingly interested in how systems learn, reason, and act across unfamiliar situations. Looking ahead, I wonder how experience can become a lasting source of capability—how a system can learn something new without losing what it already knows.
Embodied AI gives this question a physical form. An action changes the world, and the world returns evidence that can refine the next decision. I hope to build systems that can learn from this exchange, allowing experience to shape both what they know and what they do.